GATE 2025 EC – Question 36
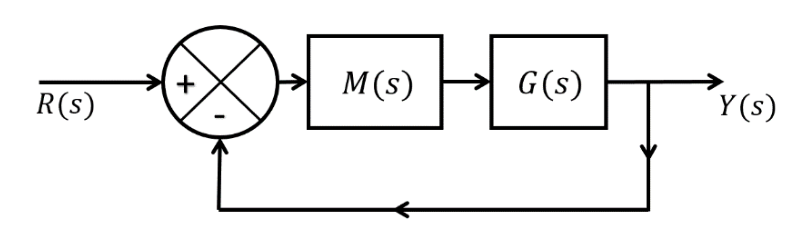
Let $G(s)=\dfrac{1}{10s^2}$ be the transfer function of a second-order system. A controller $M(s)$ is connected to the system $G(s)$ in the configuration shown below.
Consider the following statements.
(i) There exists no controller of the form $M(s)=\dfrac{K_I}{s}$, where $K_I$ is a positive real number, such that the closed loop system is stable.
(ii) There exists at least one controller of the form $M(s)=K_P+sK_D$, where $K_P$ and $K_D$ are positive real numbers, such that the closed loop system is stable.
Which one of the following options is correct?
Practise this question in The GATE Grind →
Show answer and explanation
Correct answer: (D) Both (i) and (ii) are TRUE
Explanation
(i) With $M=K_I/s$ the characteristic equation is $1+\dfrac{K_I}{10s^3}=0$, i.e. $10s^3+K_I=0$. It has a missing $s^2$ and $s$ term, so it has roots in the right half-plane for every $K_I>0$: no stabilising controller, statement TRUE. (ii) With $M=K_P+sK_D$ the characteristic equation is $10s^2+K_Ds+K_P=0$. For a second-order polynomial all coefficients positive means stable, so any $K_P,K_D>0$ works: statement TRUE.